2026 video · Hardware demonstration
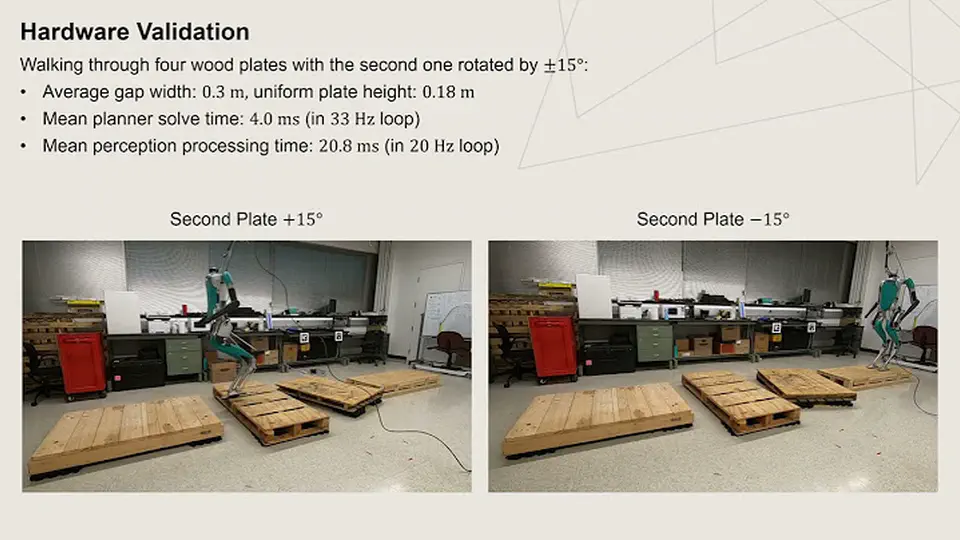
Walking across disconnected footholds
Depth-based foothold perception and variable step timing guide Digit across separated platforms.
Cyberbotics Lab · The Ohio State University
We study how humanoid robots and exoskeletons balance, move, and adapt. Our research combines dynamics, control, optimization, and learning, connecting mathematical models with simulation and robot experiments.
Mechanical and Aerospace Engineering
Columbus, Ohio
Lab software platform
A modular foundation for robotics research.
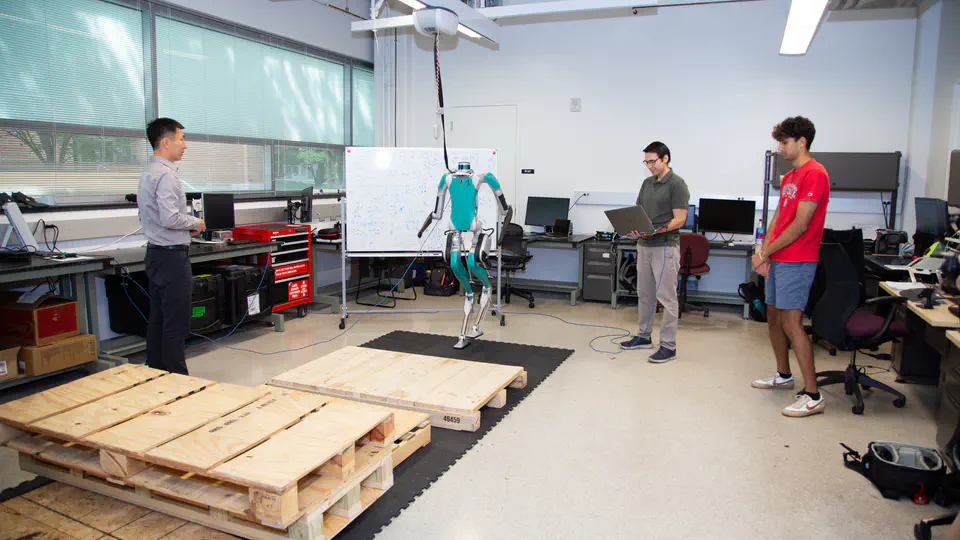
Our robotics software platform connects robot models, motion planning, whole-body control, and learning through a C++ core and Python interfaces.
The repository is not public yet. Public release details will be announced here.
Research in motion
2026 video · Hardware demonstration
Depth-based foothold perception and variable step timing guide Digit across separated platforms.
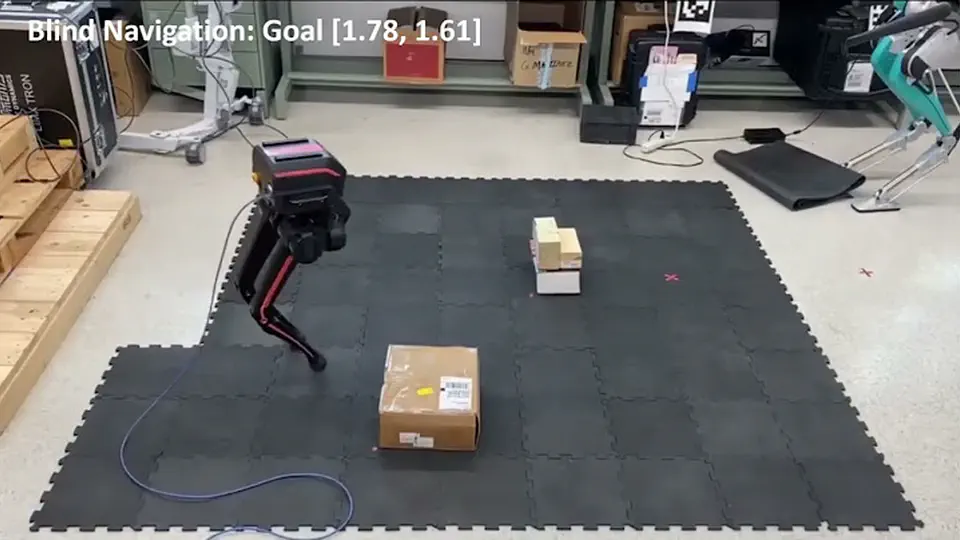
2026 video · Hardware demonstration
A learned planner selects intermediate goals for Digit navigation around obstacles.
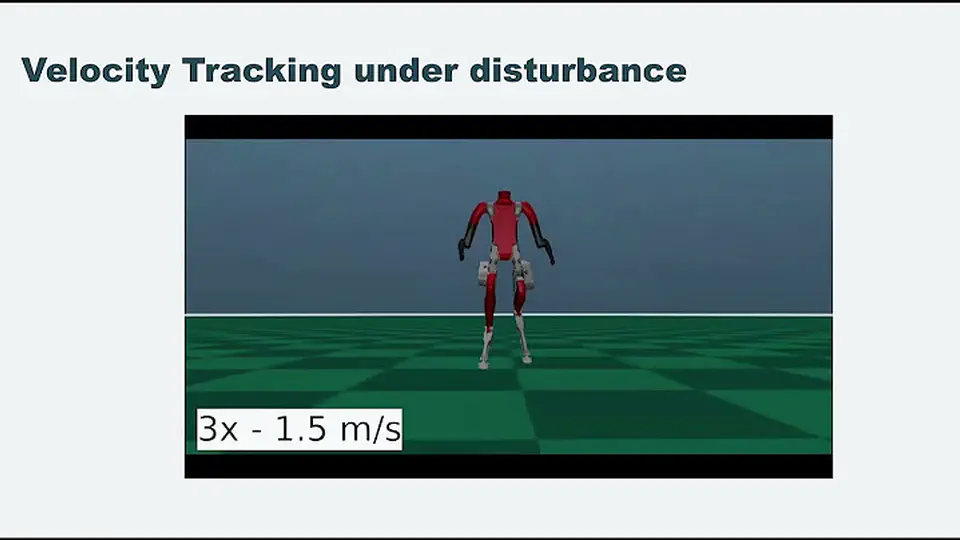
2026 video · Simulation
Reduced-order predictions guide policy learning and foot-placement filtering in Digit simulation.
Also explore exoskeleton walking, whole-body control, and disturbance-rejection testing.
What we study
Perception → planning → walking
Connect terrain perception and obstacle avoidance with feasible steps, step timing, and whole-body motion.
Explore this researchModels + learning
Combine reduced-order models, feedback control, and learned policies; evaluate stability and safety under stated conditions.
Explore this researchHuman–robot dynamics
Develop dynamic walking controllers for powered lower-limb exoskeletons and study balance in coupled human–robot systems.
Explore this researchMethods → reusable tools
Connect robot models, planning, control, and learning through Cyber Suite's modular C++ and Python foundation.
Explore this researchSafety evaluation connects these areas: see our work on testing legged robots.
Recent work
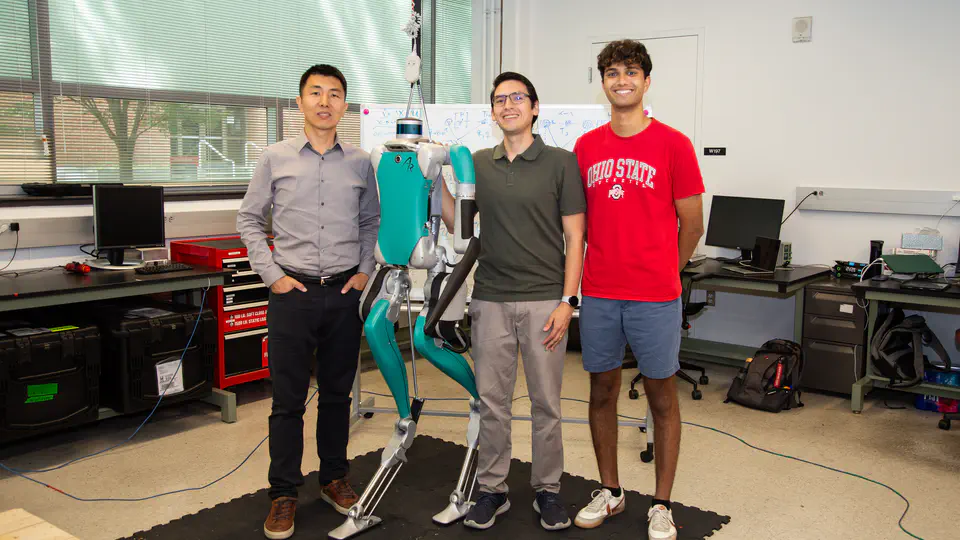
People behind the research
Led by Ayonga Hereid, Associate Professor of Mechanical and Aerospace Engineering at Ohio State, our group studies the dynamics, control, and learning of walking robots.