Research project
Self-Balancing Exoskeletons
Powered exoskeletons must coordinate walking and balance in a coupled human–robot system. We adapt dynamic locomotion methods to study gait generation and feedback control for lower-limb assistance.
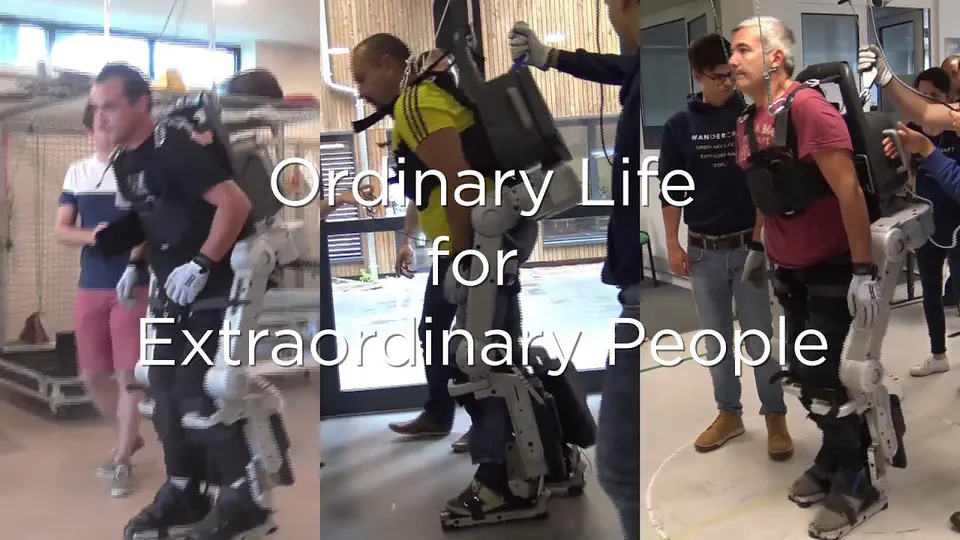
- Model the coupled human–robot system
- Generate dynamic walking gaits
- Control motion and balance
The problem
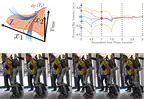
A powered lower-limb exoskeleton must support walking while balancing the coupled human–robot system. Controller design must account for hybrid contact dynamics and differences between users.
Our approach
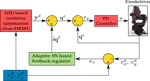
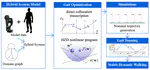
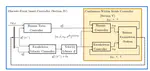
We translate hybrid zero dynamics and trajectory optimization methods from bipedal robots to exoskeletons. Related work studies gait generation, feedback control, and adaptation to model uncertainty.
Results and experimental setting
The linked ATALANTE studies report dynamic walking experiments with human participants, including walking without crutches in the reported experimental setting. These studies establish controller results under their stated conditions; they do not establish broad clinical efficacy, rehabilitation outcomes, or suitability for every user.
Papers and demonstrations
- Towards restoring locomotion for paraplegics (2018)
- Feedback control of an exoskeleton for paraplegics (2018)
- Adaptive neural-network control (2021)
Watch the exoskeleton demonstration.
The gallery also includes early walking with the Ohio State controller.