Research project
FROST
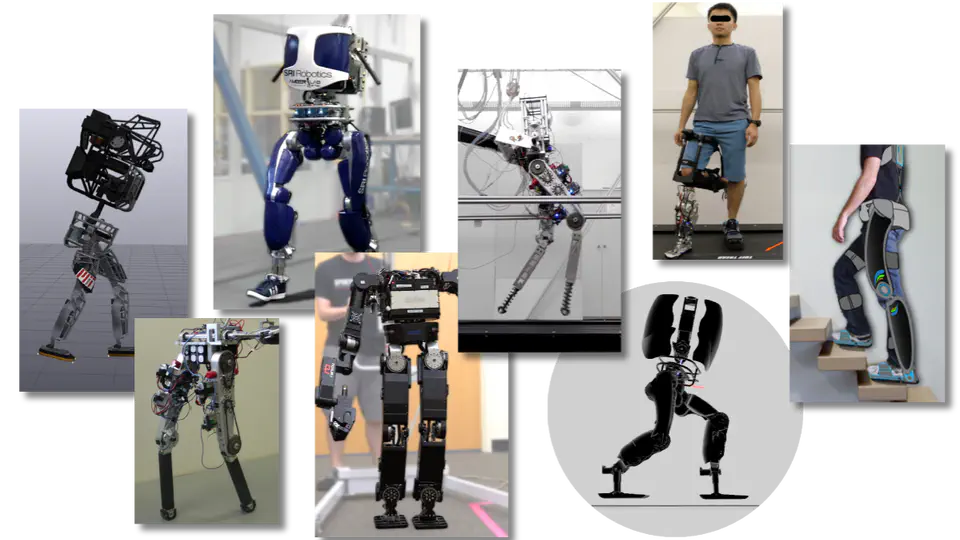
Dynamic walking requires models that capture motion and contact transitions. FROST brings hybrid-system modeling, constrained gait optimization, and simulation into an open-source MATLAB toolkit.
- Model hybrid robot dynamics
- Optimize constrained trajectories
- Simulate and evaluate the motion
The problem
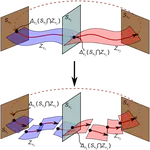
Dynamic walking combines continuous motion with discrete contact transitions. Generating a gait requires a model that represents this hybrid structure and enforces the robot’s dynamics and constraints.
Our approach
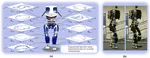
FROST is an open-source MATLAB toolkit for hybrid-system modeling, trajectory optimization, and simulation. It represents discrete structure using directed graphs, supports symbolic model generation, and uses direct collocation to formulate constrained trajectory optimization problems.
Results and experimental setting
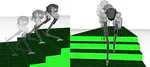
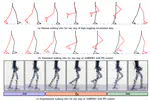
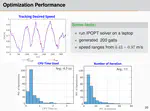
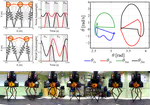
The FROST paper describes gait synthesis for multiple bipedal models and presents simulation case studies. Optimization performance and deployment requirements depend on the model, formulation, solver, and computing environment.
Use the toolkit
Start with an example that matches your robot model and record the software version, solver settings, and problem formulation when reporting results.
Publications