Research direction
Full-Body Exoskeleton Control
Full-body exoskeletons link a person's motion with an actuated mechanical system. This research direction explores how hybrid walking models and feedback control could support balance in that coupled system.
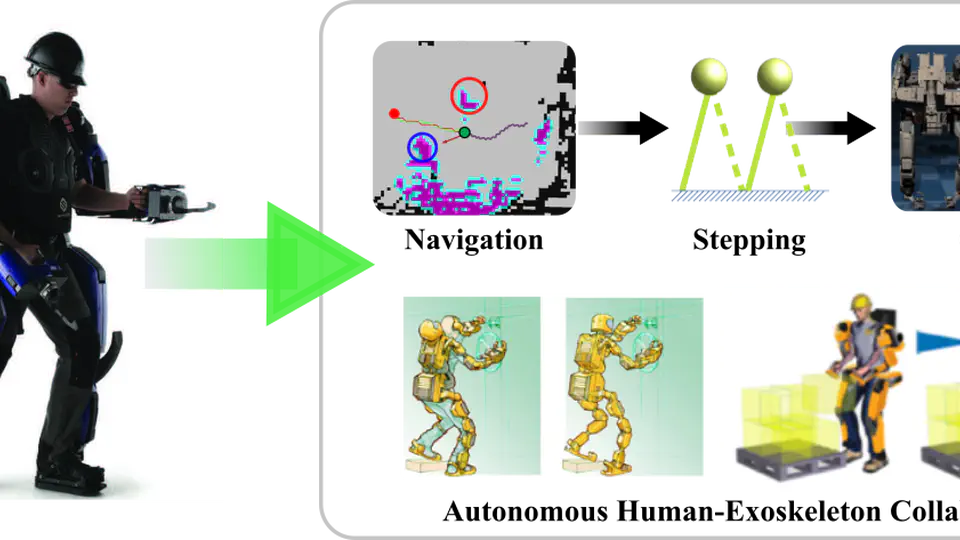
- Study coupled human–robot dynamics
- Explore hybrid gait generation
- Investigate balance control
The problem
Full-body powered exoskeletons couple a person’s motion with an actuated mechanical system. Locomotion control must account for balance, contact transitions, and the interaction between the two.
Research direction
This project explores how hybrid locomotion methods developed for bipedal robots could inform industrial full-body exoskeleton control. Reduced-order walking models, gait generation, and feedback control provide a basis for studying this problem.
Evidence and scope
Related lab papers establish control methods on bipedal robots and lower-limb exoskeletons. Industrial full-body assistance remains a research direction on this page. Those results do not establish a validated deployment of an industrial full-body exoskeleton or a demonstrated increase in worker productivity.
