Research project
Perceptive Locomotion & Navigation
A humanoid must choose where to go and where to step. We connect terrain perception, reduced-order walking models, and constrained planning to make those decisions together.
- Identify paths and steppable terrain
- Plan footsteps, subgoals, and timing
- Coordinate walking and navigation
The problem
A walking robot must choose steps that respect both its dynamics and the environment. Obstacle-free paths can still demand infeasible foot placements, and disconnected footholds leave little room for timing errors.
Our approach
We connect reduced-order walking models with constrained planning. This includes joint path and gait planning with control barrier functions, adaptive step duration for restricted footholds, and depth-based construction of steppable regions.
Results and experimental setting
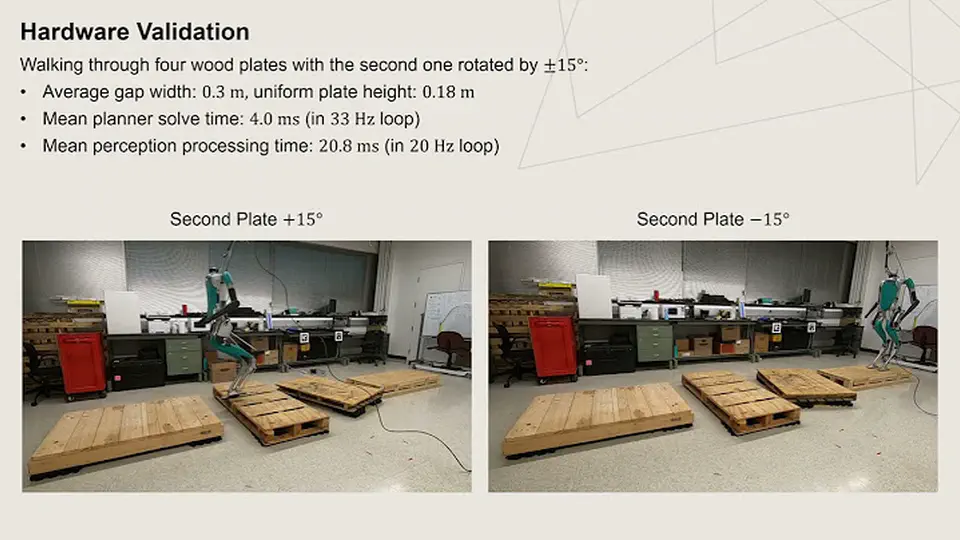
- Footstep planning: The adaptive-timing and perceptive-planning manuscripts evaluate Digit in simulation, including restricted footholds, depth sensing, and stepping-stone layouts.
- Navigation: The linked studies connect path or subgoal selection with a walking planner and evaluate obstacle-navigation scenarios in simulation.
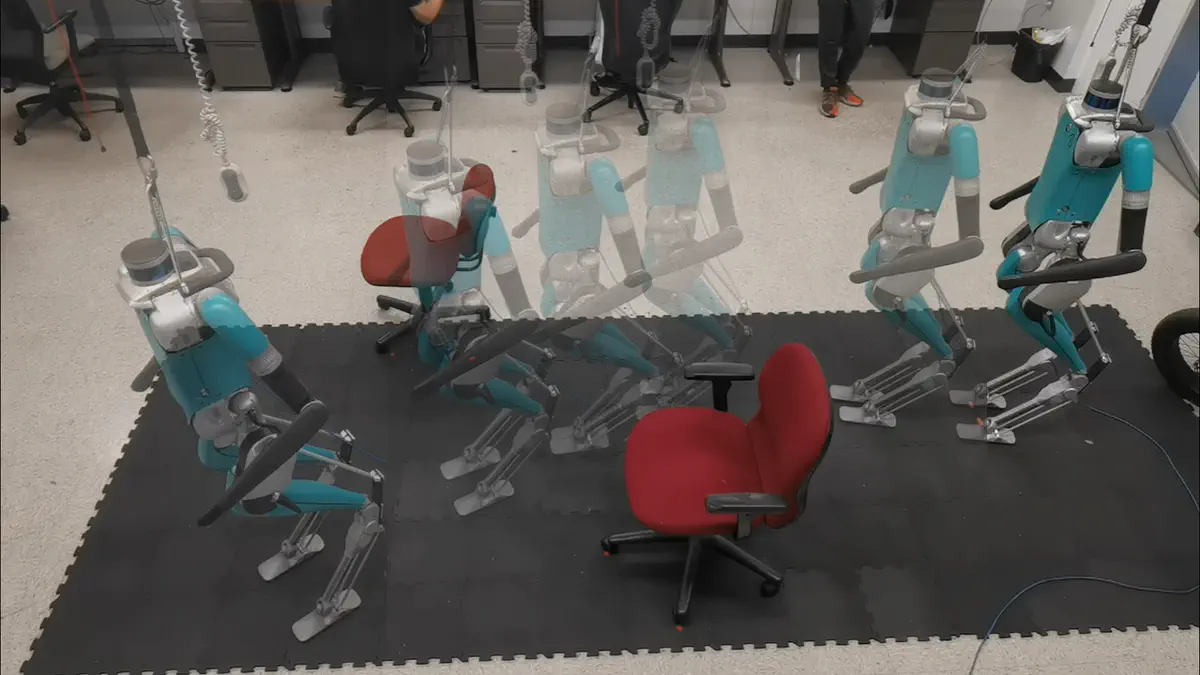
- Recent lab demonstrations: The October 2026 videos show Digit hardware demonstrations of perceptive stepping and learned-subgoal navigation. These later clips are presented alongside the original papers’ reported evaluations.
Scope: Results describe the models, terrain, obstacles, and experimental conditions in the linked studies and demonstrations.
Papers and demonstrations
- Perceptive variable-timing footstep planning (2026 preprint)
- Learning navigation with dynamic subgoals (2025 preprint)
- Adaptive step duration (IROS 2025)
- Real-time safe navigation (ICRA 2025)
- Unified path and gait planning (2024 preprint)
Watch perceptive footstep planning and learned-subgoal navigation. The earlier adaptive-timing simulation shows the planning method on restricted footholds.
Explore the planning framework