Research project
Safety Testing for Legged Robots
Repeatable tests make locomotion controllers easier to compare. We develop disturbance-testing methods and evaluation procedures that specify the task, perturbation, and measure of success.
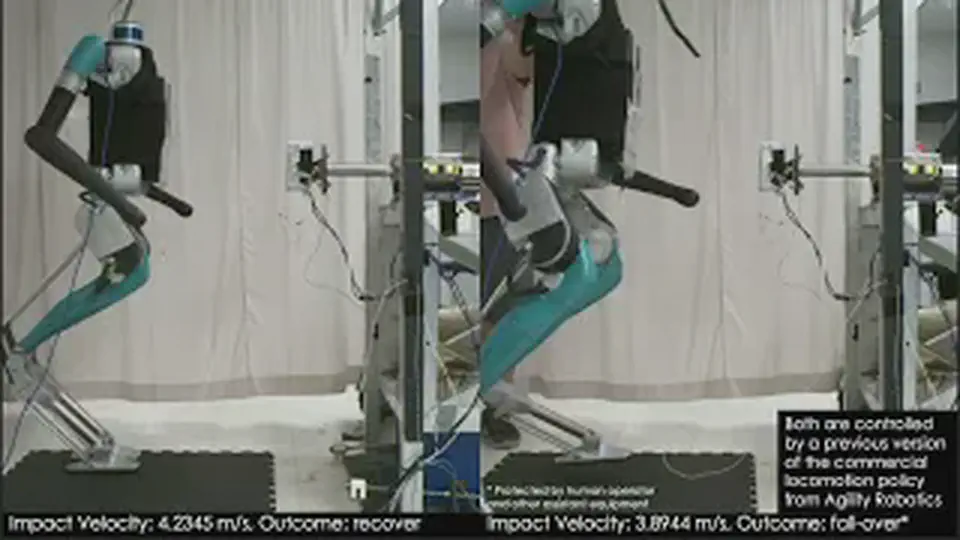
- Define the task and disturbance
- Apply repeatable perturbations
- Compare controller outcomes
The problem
Hand pushes and informal demonstrations are difficult to reproduce. Comparing locomotion controllers requires controlled disturbances, explicit test conditions, and a defined measure of success.
Our approach
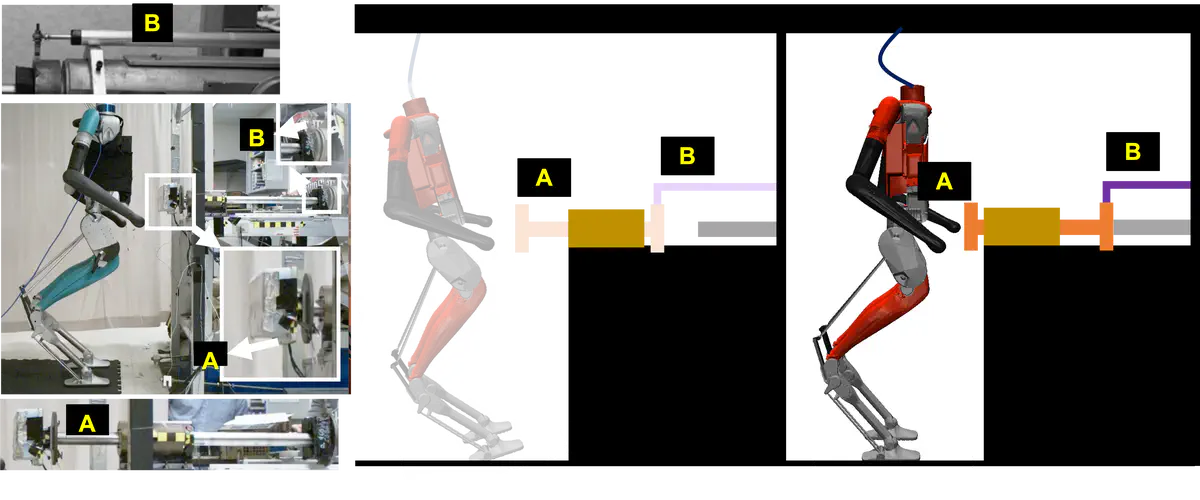
We study repeatable testing equipment and procedures for legged locomotion, including linear-impactor experiments, sampling-based safety evaluation, and controller comparisons.
Results and experimental setting
The preliminary linear-impactor study compares three Digit locomotion controllers during walking in place under frontal impacts. Its findings concern that experimental setup and task. They do not certify general robot safety or performance for every direction, speed, or terrain.
Papers and demonstrations
Explore the testing configuration