Research
Publications
People
Resources
Join & Collaborate
1
Adaptive Step Duration for Accurate Foot Placement: Achieving Robust Bipedal Locomotion on Terrains with Restricted Footholds
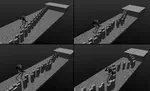
Simulation study of adaptive step timing and foot placement on constrained stepping-stone terrain.
Zhaoyang Xiang
,
Victor Paredes
,
Guillermo A Castillo
,
Ayonga Hereid
PDF
Cite
Project
Video
DOI
arXiv
Real-time safe bipedal robot navigation using linear discrete control barrier functions
Digit simulation study of obstacle avoidance with linear discrete control barrier functions.
Chengyang Peng
,
Victor Paredes
,
Guillermo A Castillo
,
Ayonga Hereid
PDF
Cite
Project
Video
DOI
arXiv
Moving past point-contacts: Extending the ALIP model to humanoids with non-trivial feet using hierarchical, full-body momentum control
The Angular-Momentum Linear Inverted Pendulum (ALIP) model is a promising motion planner for bipedal robots. However, it relies on two …
Victor C Paredes
,
Daniel A Hagen
,
Samuel W Chesebrough
,
Riley Swann
,
Denis Garagić
,
Ayonga Hereid
PDF
Cite
Project
IEEE
Safe whole-body task space control for humanoid robots
Complex robotic systems require whole-body controllers to handle contact interactions, handle closed kinematic chains, and track …
Victor C Paredes
,
Ayonga Hereid
PDF
Cite
Project
Video
IEEE
Data-driven latent space representation for robust bipedal locomotion learning
This paper presents a novel framework for learning robust bipedal walking by combining a data-driven state representation with a …
Guillermo A Castillo
,
Bowen Weng
,
Wei Zhang
,
Ayonga Hereid
PDF
Cite
Project
Video
IEEE
Template model inspired task space learning for robust bipedal locomotion
This work presents a hierarchical framework for bipedal locomotion that combines a Reinforcement Learning (RL)-based high-level (HL) …
Guillermo A Castillo
,
Bowen Weng
,
Shunpeng Yang
,
Wei Zhang
,
Ayonga Hereid
PDF
Cite
Project
Video
arXiv
Towards standardized disturbance rejection testing of legged robot locomotion with linear impactor: A preliminary study, observations, and implications
Dynamic locomotion in legged robots is close to industrial collaboration, but a lack of standardized testing obstructs …
Bowen Weng
,
Guillermo A Castillo
,
Yun-Seok Kang
,
Ayonga Hereid
PDF
Cite
Project
Video
IEEE
Time-Varying ALIP Model and Robust Foot-Placement Control for Underactuated Bipedal Robotic Walking on a Swaying Rigid Surface
Controller design for bipedal walking on dynamic rigid surfaces (DRSes), which are rigid surfaces moving in the inertial frame (e.g., …
Yuan Gao
,
Yukai Gong
,
Victor Paredes
,
Ayonga Hereid
,
Yan Gu
PDF
Cite
Project
IEEE
arXiv
Safe Bipedal Path Planning via Control Barrier Functions for Polynomial Shape Obstacles Estimated Using Logistic Regression
Safe path planning is critical for bipedal robots to operate in safety-critical environments. Common path planning algorithms, such as …
Chengyang Peng
,
Octavian Donca
,
Guillermo Castillo
,
Ayonga Hereid
PDF
Cite
Project
Video
IEEE
On safety testing, validation, and characterization with scenario-sampling: A case study of legged robots
The dynamic response of the legged robot locomotion is non-Lipschitz and can be stochastic due to environmental uncertainties. To test, …
Bowen Weng
,
Guillermo A Castillo
,
Wei Zhang
,
Ayonga Hereid
PDF
Cite
Project
IEEE
»
Cite
×