Research
Publications
People
Resources
Join & Collaborate
1
Resolved motion control for 3d underactuated bipedal walking using linear inverted pendulum dynamics and neural adaptation
We present a framework to generate periodic trajectory references for a 3D under-actuated bipedal robot, using a linear inverted …
Victor C Paredes
,
Ayonga Hereid
PDF
Cite
Video
IEEE
Learning linear policies for robust bipedal locomotion on terrains with varying slopes
In this paper, with a view toward deployment of light-weight control frameworks for bipedal walking robots, we realize end-foot …
Lokesh Krishna
,
Utkarsh A Mishra
,
Guillermo A Castillo
,
Ayonga Hereid
,
Shishir Kolathaya
PDF
Cite
Video
IEEE
Robust feedback motion policy design using reinforcement learning on a 3d digit bipedal robot
In this paper, a hierarchical and robust framework for learning bipedal locomotion is presented and successfully implemented on the 3D …
Guillermo A Castillo
,
Bowen Weng
,
Wei Zhang
,
Ayonga Hereid
PDF
Cite
Project
Video
IEEE
Dynamic locomotion of a lower-limb exoskeleton through virtual constraints based zmp regulation
Robotic lower-limb exoskeletons have the potentials to assist individuals with paraplegia to perform normal ambulatory functions and to …
Victor Paredes
,
Ayonga Hereid
PDF
Cite
Project
Video
ASME
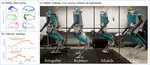
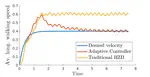
Velocity regulation of 3d bipedal walking robots with uncertain dynamics through adaptive neural network controller
This paper presents a neural-network based adaptive feedback control structure to regulate the velocity of 3D bipedal robots under …
Guillermo A Castillo
,
Bowen Weng
,
Terrence C Stewart
,
Wei Zhang
,
Ayonga Hereid
PDF
Cite
Project
IEEE
Hybrid zero dynamics inspired feedback control policy design for 3d bipedal locomotion using reinforcement learning
This paper presents a novel model-free reinforcement learning (RL) framework to design feedback control policies for 3D bipedal …
Guillermo A Castillo
,
Bowen Weng
,
Wei Zhang
,
Ayonga Hereid
PDF
Cite
Project
Video
IEEE
Algorithmic foundations of realizing multi-contact locomotion on the humanoid robot DURUS
This paper presents the meta-algorithmic approach used to realize multi-contact walking on the humanoid robot, DURUS. This systematic …
Jacob P Reher
,
Ayonga Hereid
,
Shishir Kolathaya
,
Christian M Hubicki
,
Aaron D Ames
PDF
Cite
Video
Springer
Reinforcement Learning Meets Hybrid Zero Dynamics: A case study for RABBIT
The design of feedback controllers for bipedal robots is challenging due to the hybrid nature of its dynamics and the complexity …
Guillermo A Castillo
,
Bowen Weng
,
Ayonga Hereid
,
Zheng Wang
,
Wei Zhang
PDF
Cite
Project
Video
IEEE
arXiv
Feedback control of a cassie bipedal robot: Walking, standing, and riding a segway
The Cassie bipedal robot designed by Agility Robotics is providing academics with a common platform for sharing and comparing …
Yukai Gong
,
Ross Hartley
,
Xingye Da
,
Ayonga Hereid
,
Omar Harib
,
Jiunn-Kai Huang
,
Jessy Grizzle
PDF
Cite
Code
Video
IEEE
arXiv
Rapid Trajectory Optimization Using C-FROST with Illustration on a Cassie-Series Dynamic Walking Biped
One of the big attractions of low-dimensional models for gait design has been the ability to compute solutions rapidly, whereas one of …
Ayonga Hereid
,
Omar Harib
,
Ross Hartley
,
Yukai Gong
,
Jessy W Grizzle
PDF
Cite
Code
Project
Video
IEEE
arXiv
«
»
Cite
×