Research
Publications
People
Resources
Join & Collaborate
3
Model-Informed Safe Reinforcement Learning for Bipedal Locomotion via Step-to-Step Prediction
Reduced-model safety certificates inform reinforcement learning and runtime foot-placement filtering in Digit simulation.
Victor Paredes
,
Ayonga Hereid
PDF
Cite
Project
Project
Video
arXiv
Perceptive Variable-Timing Footstep Planning for Humanoid Locomotion on Disconnected Footholds
Depth-based steppable regions and variable-timing planning evaluated in Digit simulation.
Zhaoyang Xiang
,
Upama Pant
,
Ayonga Hereid
PDF
Cite
Project
Video
arXiv
Reinforcement learning with data bootstrapping for dynamic subgoal pursuit in humanoid robot navigation
Data-bootstrapped reinforcement learning selects navigation subgoals for an MPC gait planner, evaluated in Digit simulation.
Chengyang Peng
,
Zhihao Zhang
,
Shiting Gong
,
Sankalp Agrawal
,
Keith A Redmill
,
Ayonga Hereid
PDF
Cite
Project
Project
Video
arXiv
Unified path and gait planning for safe bipedal robot navigation
Unified path and gait planning evaluated in Digit simulation with randomly generated obstacles.
Chengyang Peng
,
Victor Paredes
,
Ayonga Hereid
PDF
Cite
Project
Video
arXiv
Real-Time Navigation for Bipedal Robots in Dynamic Environments
The popularity of mobile robots has been steadily growing, with these robots being increasingly utilized to execute tasks previously …
Octavian Donca
,
Chayapol Beokhaimook
,
Ayonga Hereid
PDF
Cite
Project
Video
arXiv
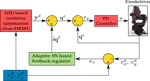
Adaptive feedback regulator for powered lower-limb exoskeleton under model uncertainty
This paper presents a neural network (NN) based adaptive feedback regulator to ensure the lateral and longitudinal stability and …
Kirtankumar Thakkar
,
Victor Paredes
,
Ayonga Hereid
PDF
Cite
Project
arXiv
Cite
×