- Publication
- IEEE Transactions on Robotics, vol. 41, pp. 5740–5760, 2025
- Type
- Journal article
Abstract
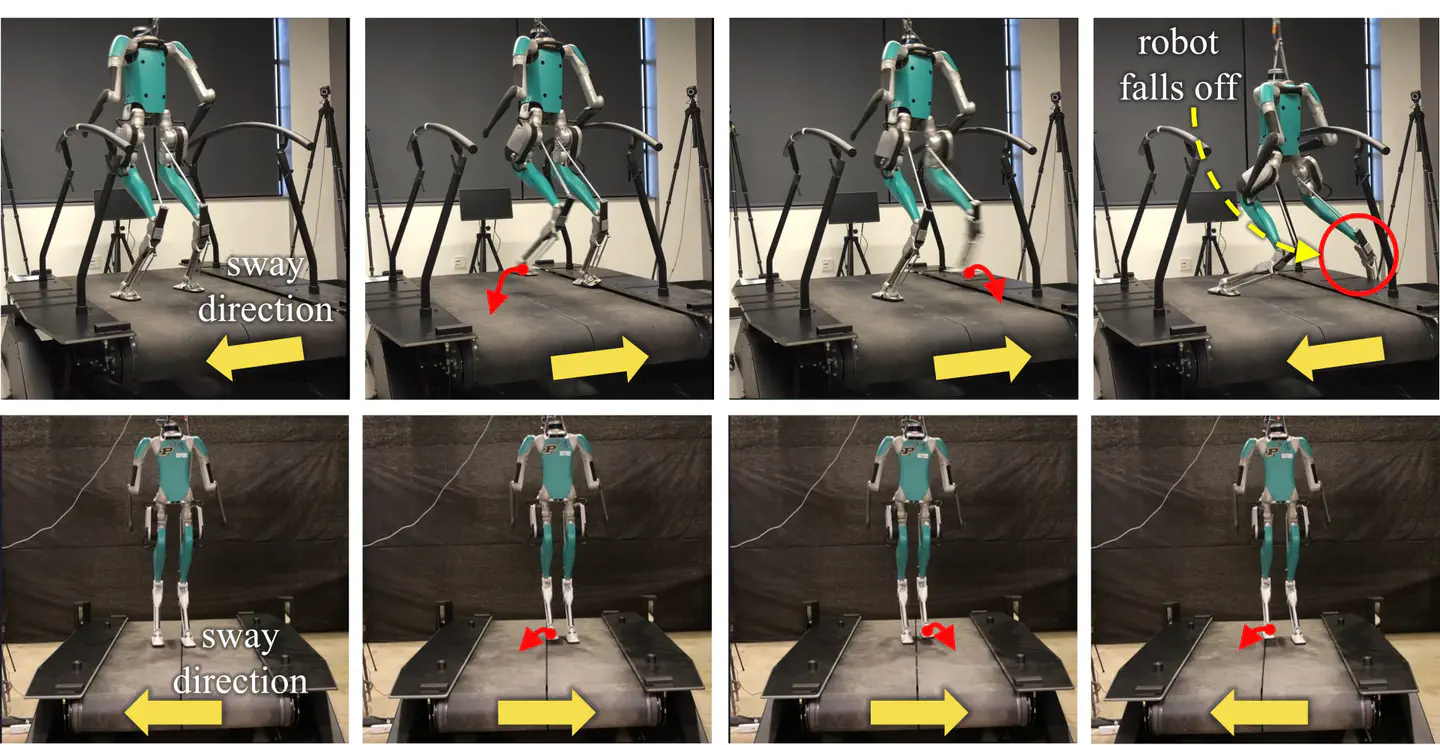
This study extends an angular-momentum-based pendulum model to periodically swaying ground and derives a time-varying foot-placement controller with sufficient stability conditions. A hierarchical framework connects the planner to robot control. Digit simulation and hardware experiments evaluate walking under surface motion, uncertain motion estimates, and external pushes. The guarantees apply under the models and conditions stated in the paper.
The page date records the first arXiv deposit. The journal publication year is 2025; the publisher record does not specify a month or day.

Victor Paredes
Ph.D. in Mechanical Engineering
I am a robotics engineer at UCR. My research endeavors are centered upon humanoids and exoskeleton devices.

Ayonga Hereid
Associate Professor of Mechanical and Aerospace Engineering
My research aims to develop computational and theoretical tools to mitigate the high dimensionality and nonlinearity present in robot control and motion planning problems.