- Publication
- IEEE International Conference on Robotics and Automation
- Type
- Conference paper
Abstract
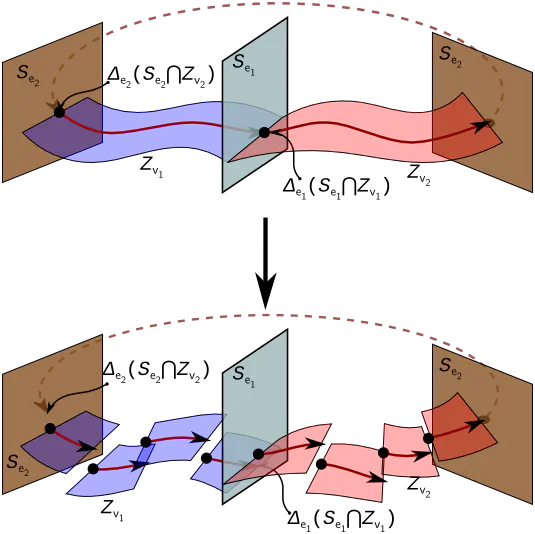
Hybrid zero dynamics (HZD) has emerged as a popular framework for the stable control of bipedal robotic gaits, but typically designing a gait virtual constraints is a slow and undependable optimization process. To expedite and boost the reliability of HZD gait generation, we borrow methods from trajectory optimization to formulate a smoother and more linear optimization problem. We present a multiple-shooting formulation for the optimization of virtual constraints, combining the stability-friendly properties of HZD with an optimization-conducive problem formulation. To showcase the implications of this recipe for improving gait generation, we use the same process to generate periodic planar walking gaits on two different robot models, and in one case, demonstrate stable walking on the hardware prototype, DURUS-R.

Ayonga Hereid
Associate Professor of Mechanical and Aerospace Engineering
My research aims to develop computational and theoretical tools to mitigate the high dimensionality and nonlinearity present in robot control and motion planning problems.