- Publication
- 2017 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
- Type
- Conference paper
Abstract
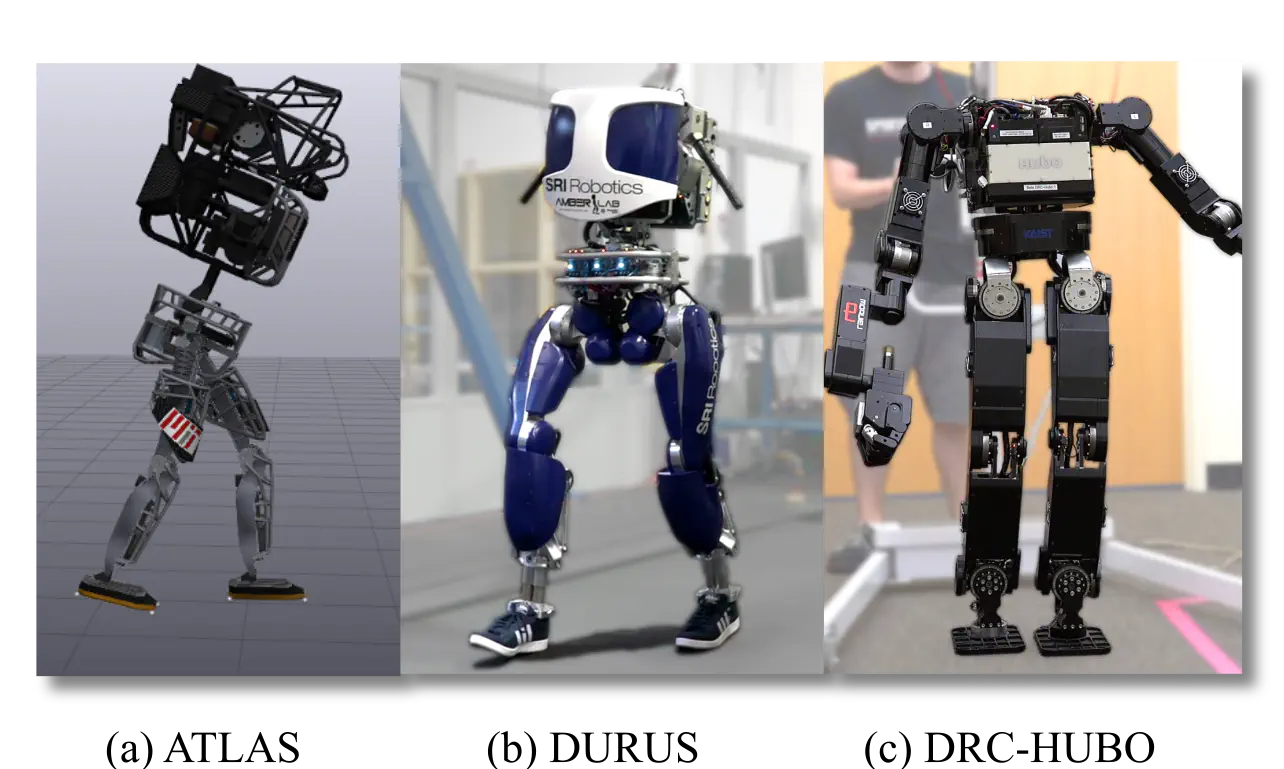
This paper presents FROST, an open-source MATLAB toolkit for modeling, trajectory optimization and simulation of hybrid dynamical systems with a particular focus in dynamic locomotion. The design objective of FROST is to provide a unified software environment for developing model-based control and motion planning algorithms for robotic systems whose dynamics is hybrid in nature. In particular, FROST uses directed graphs to describe the underlying discrete structure of hybrid system models, which renders it capable of representing a wide variety of robotic systems. Equipped with a custom symbolic math toolbox in MATLAB using Wolfram Mathematica, one can rapidly prototype the mathematical model of robot kinematics and dynamics and generate optimized code of symbolic expressions to boost the speed of optimization and simulation in FROST. In favor of agile and dynamic behaviors, we utilize virtual constraint based motion planning and feedback controllers for robotic systems to exploit the full-order dynamics of the model. Moreover, FROST provides a fast and tractable framework for planning optimal trajectories of hybrid dynamical systems using advanced direct collocation algorithms. FROST has been successfully used to synthesize dynamic walking in multiple bipedal robots. Case studies of such applications are considered in this paper, wherein different types of walking gaits are generated for two specific humanoid robots and validated in simulation.

Ayonga Hereid
Associate Professor of Mechanical and Aerospace Engineering
My research aims to develop computational and theoretical tools to mitigate the high dimensionality and nonlinearity present in robot control and motion planning problems.