- Publication
- 2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
- Type
- Conference paper
Abstract
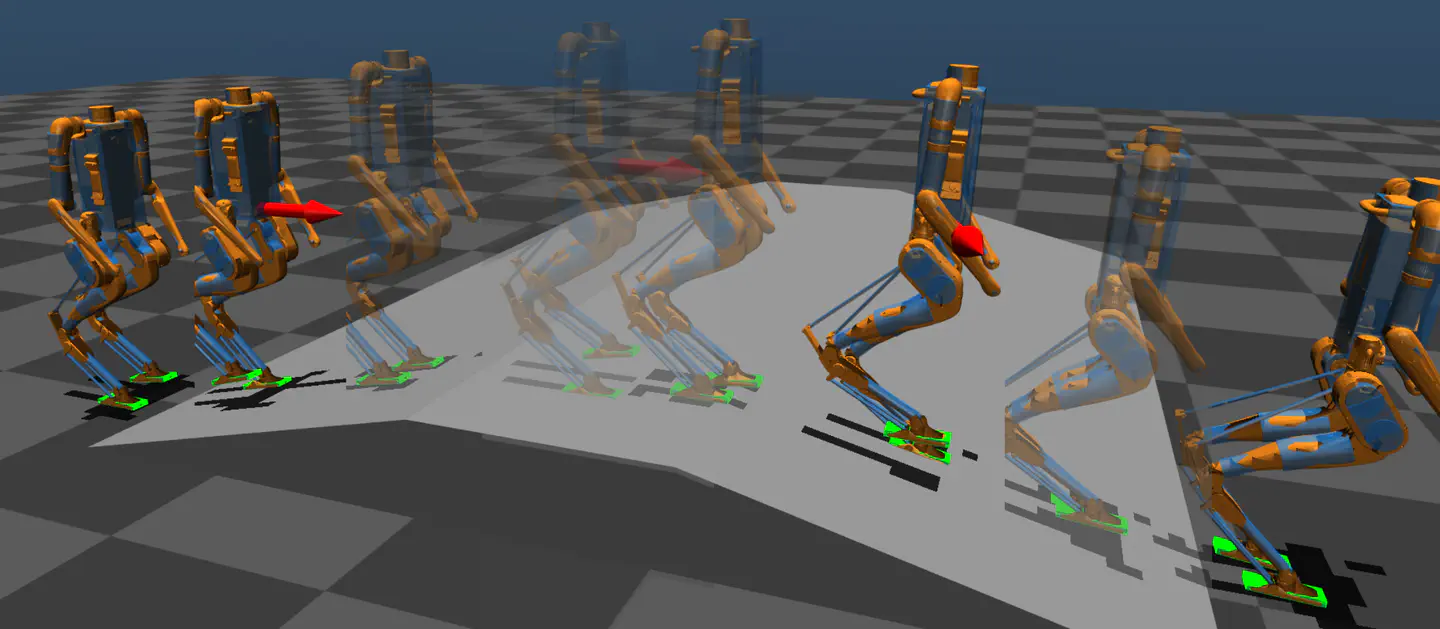
In this paper, with a view toward deployment of light-weight control frameworks for bipedal walking robots, we realize end-foot trajectories that are shaped by a single linear feedback policy. We learn this policy via a model-free and a gradient free learning algorithm, Augmented Random Search (ARS), in the two robot platforms Rabbit and Digit. Our contributions are two-fold. a) By using torso and support plane orientation as inputs, we achieve robust walking on slopes of upto 20 degrees in simulation. b) We demonstrate additional behaviors like walking backwards, stepping-in-place, and recovery from external pushes of upto 120 N. The end-result is a robust and a fast feedback control law for bipedal walking on terrains with varying slopes. Towards the end, we also provide preliminary results of hardware transfer to Digit.

Guillermo A Castillo
Ph.D. in Electrical and Computer Engineering
I am a robotics engineer at Apptronik.

Ayonga Hereid
Associate Professor of Mechanical and Aerospace Engineering
My research aims to develop computational and theoretical tools to mitigate the high dimensionality and nonlinearity present in robot control and motion planning problems.