- Publication
- 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 6607–6613
- Type
- Conference paper
Abstract
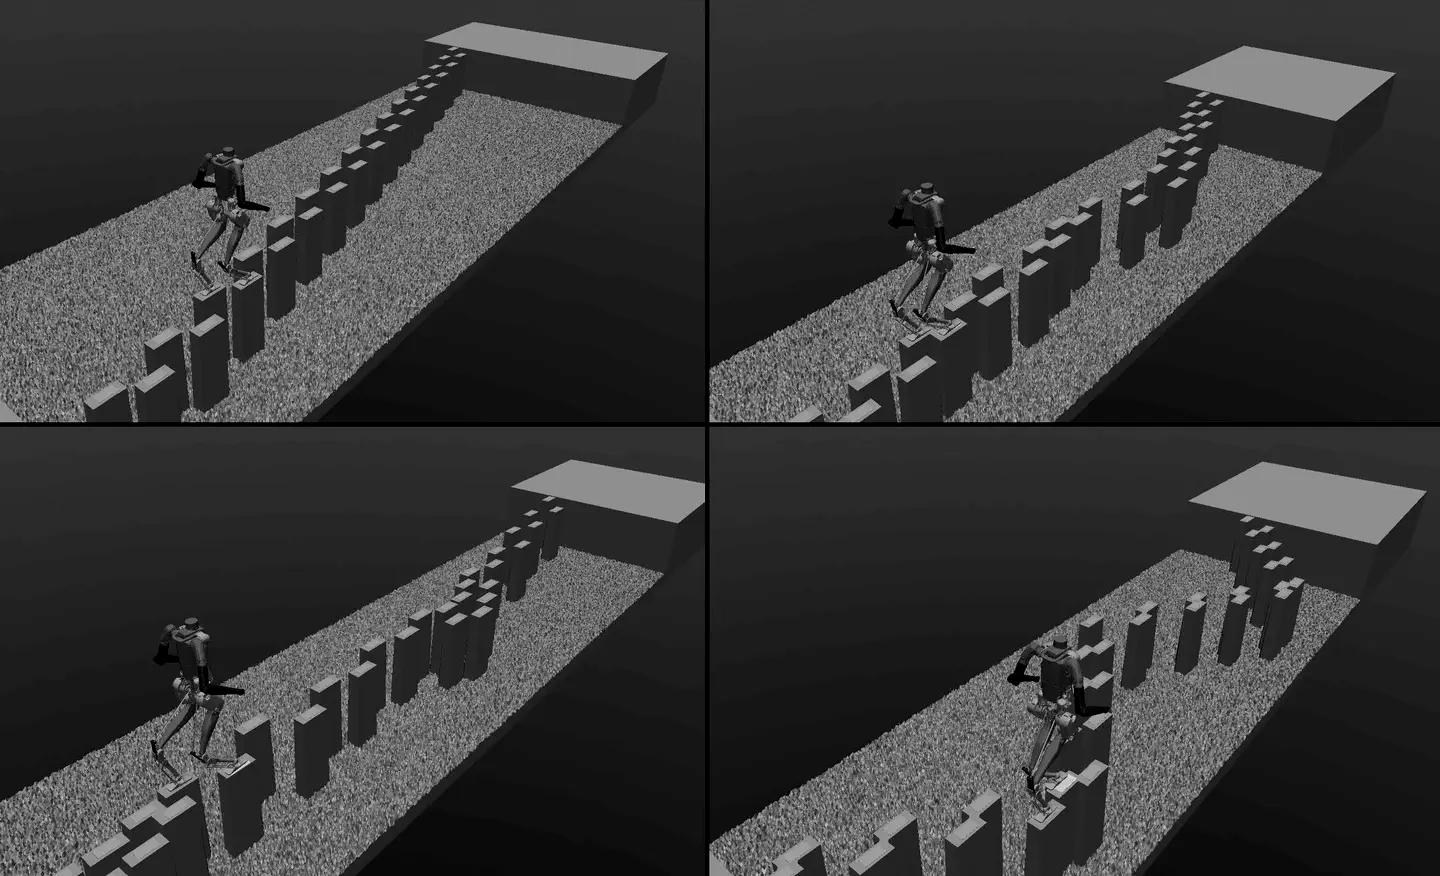
Traditional one-step preview planning algorithms for bipedal locomotion struggle to generate viable gaits when walking across terrains with restricted footholds, such as stepping stones. To overcome such limitations, this paper introduces a novel multi-step preview foot placement planning algorithm based on the step-to-step discrete evolution of the Divergent Component of Motion (DCM) of walking robots. Our proposed approach adaptively changes the step duration and the swing foot trajectory for optimal foot placement under constraints, thereby enhancing the long-term stability of the robot and significantly improving its ability to navigate environments with tight constraints on viable footholds. We demonstrate its effectiveness through various simulation scenarios with complex stepping-stone configurations and external perturbations. These tests underscore its improved performance for navigating foothold-restricted terrains, even with external disturbances.

Zhaoyang Xiang
Ph.D. Candidate
My research interests include bipedal robotic walking, model-based robotic locomotion planning and control.

Victor Paredes
Ph.D. in Mechanical Engineering
I am a robotics engineer at UCR. My research endeavors are centered upon humanoids and exoskeleton devices.

Guillermo A Castillo
Ph.D. in Electrical and Computer Engineering
I am a robotics engineer at Apptronik.

Ayonga Hereid
Associate Professor of Mechanical and Aerospace Engineering
My research aims to develop computational and theoretical tools to mitigate the high dimensionality and nonlinearity present in robot control and motion planning problems.