Research
Publications
People
Resources
Join & Collaborate
adaptive planning
Adaptive Step Duration for Accurate Foot Placement: Achieving Robust Bipedal Locomotion on Terrains with Restricted Footholds
Simulation study of adaptive step timing and foot placement on constrained stepping-stone terrain.
Zhaoyang Xiang
,
Victor Paredes
,
Guillermo A Castillo
,
Ayonga Hereid
PDF
Cite
Project
Video
DOI
arXiv
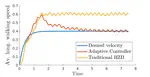
Velocity regulation of 3d bipedal walking robots with uncertain dynamics through adaptive neural network controller
This paper presents a neural-network based adaptive feedback control structure to regulate the velocity of 3D bipedal robots under …
Guillermo A Castillo
,
Bowen Weng
,
Terrence C Stewart
,
Wei Zhang
,
Ayonga Hereid
PDF
Cite
Project
IEEE
Cite
×