Research
Publications
People
Resources
Join & Collaborate
dynamic rigid surface
Time-varying foot placement control for humanoid walking on swaying rigid surface
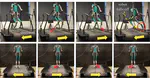
Digit hardware and simulation experiments on periodically swaying ground.
Yuan Gao
,
Victor Paredes
,
Yukai Gong
,
Zijian He
,
Ayonga Hereid
,
Yan Gu
PDF
Cite
Project
Video
DOI
arXiv
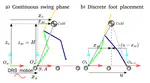
Time-Varying ALIP Model and Robust Foot-Placement Control for Underactuated Bipedal Robotic Walking on a Swaying Rigid Surface
Controller design for bipedal walking on dynamic rigid surfaces (DRSes), which are rigid surfaces moving in the inertial frame (e.g., …
Yuan Gao
,
Yukai Gong
,
Victor Paredes
,
Ayonga Hereid
,
Yan Gu
PDF
Cite
Project
IEEE
arXiv
Cite
×