Research
Publications
People
Resources
Join & Collaborate
humanoid
Perceptive Humanoid Locomotion and Autonomous Navigation
Perception-aware footstep planning and navigation for humanoid robots.
Safety Testing of Legged Robots
Repeatable disturbance-rejection testing and comparison of legged robot controllers.
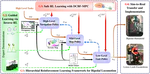
Hierarchical Reinforcement Learning (HRL) for Safe Dynamic Legged Locomotion
Model-informed learning methods for dynamic bipedal locomotion.
Cite
×