Research
Publications
People
Resources
Join & Collaborate
pseudospectral collocation
Online optimal gait generation for bipedal walking robots using legendre pseudospectral optimization
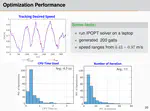
This paper presents an optimal gait synthesis method that exploits the full body dynamics of robots using the Hybrid Zero Dynamics …
Ayonga Hereid
,
Shishir Kolathaya
,
Aaron D Ames
PDF
Cite
Project
Video
IEEE
Cite
×