Research
Publications
People
Resources
Join & Collaborate
robot design
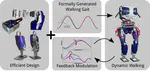
Realizing dynamic and efficient bipedal locomotion on the humanoid robot DURUS
This paper presents the methodology used to achieve efficient and dynamic walking behaviors on the prototype humanoid robotics …
Jacob Reher
,
Eric A Cousineau
,
Ayonga Hereid
,
Christian M Hubicki
,
Aaron D Ames
PDF
Cite
Video
IEEE
Cite
×