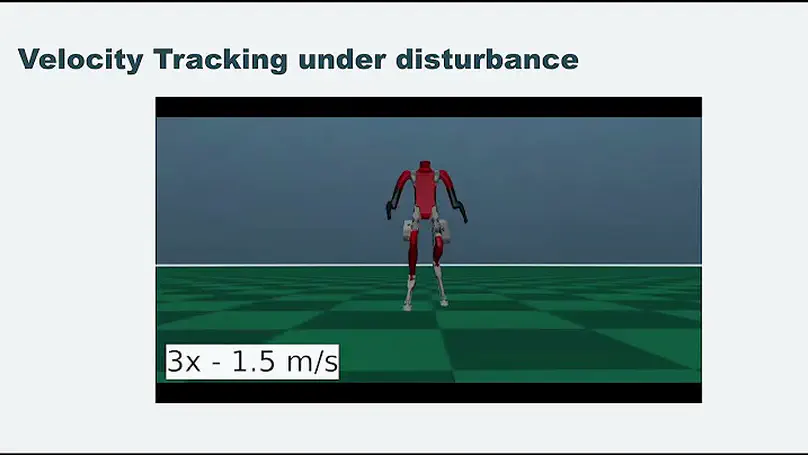
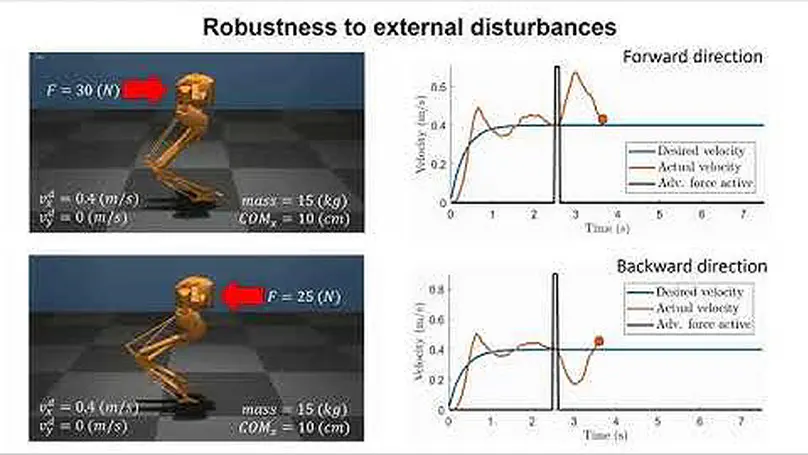
Step-to-step prediction informs reinforcement learning for bipedal locomotion.
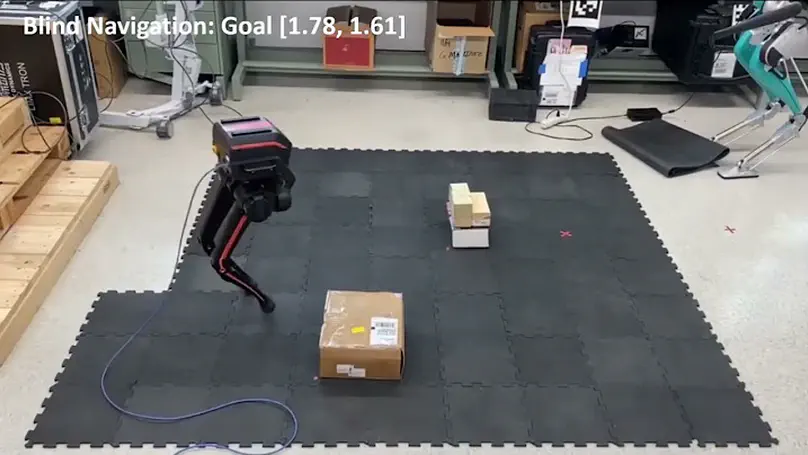
Dynamic subgoals guide humanoid robot navigation.
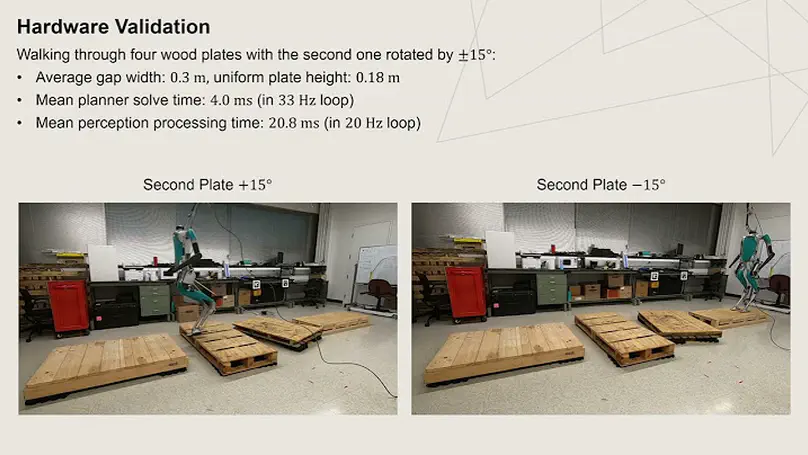
Perception and variable step timing for walking across disconnected footholds.
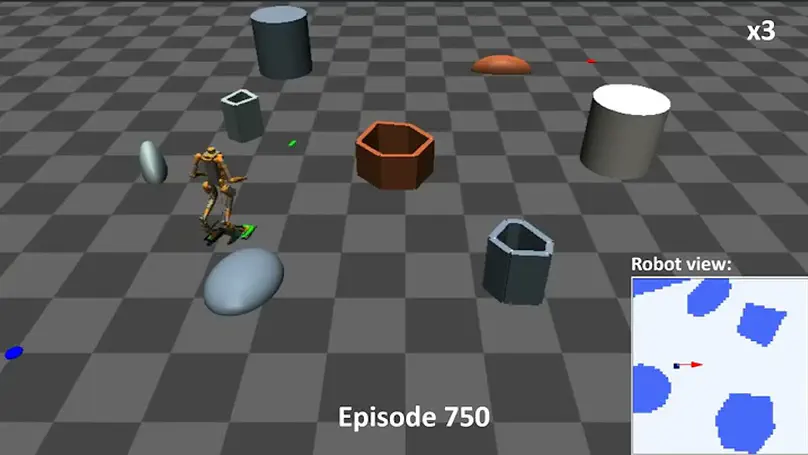
Data bootstrapping supports reinforcement learning for dynamic navigation subgoals.
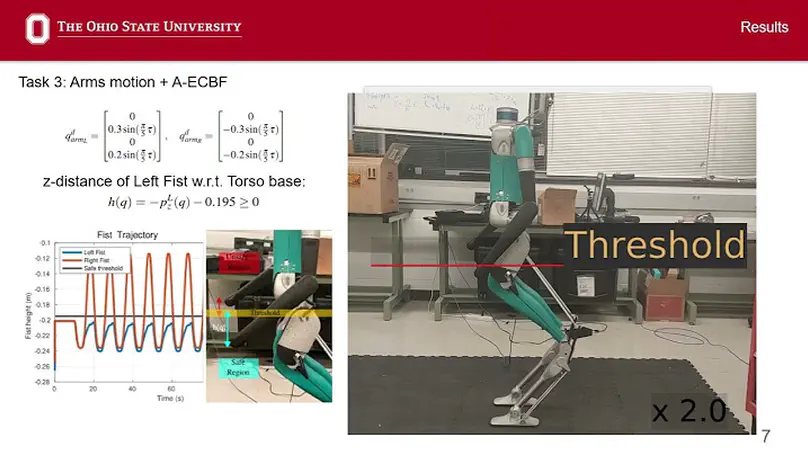
Linear discrete control barrier functions for safe bipedal robot navigation.
Whole-body task-space control for humanoid robots.
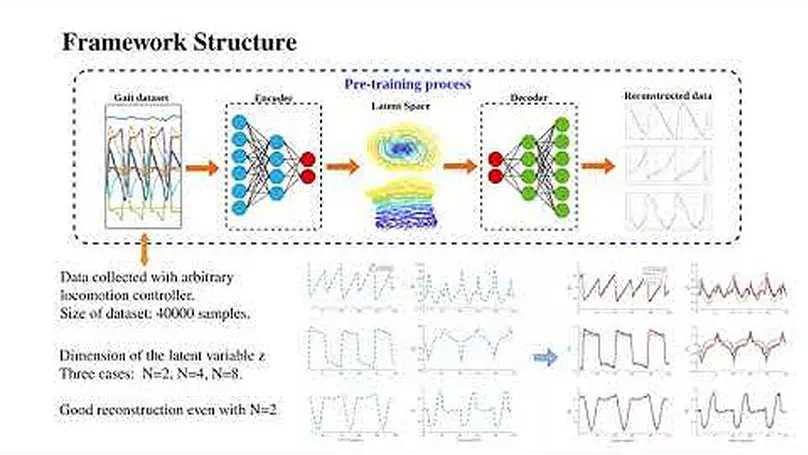
A data-driven latent representation supports bipedal locomotion learning.
Template models inform task-space learning for bipedal locomotion.
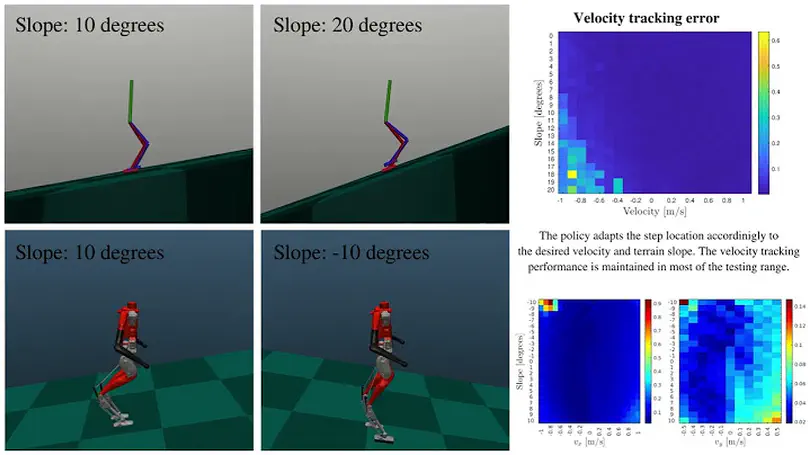
Adaptive neural feedback regulates bipedal walking velocity.
Disturbance-rejection testing of legged locomotion with a linear impactor.