Video Gallery (selected)



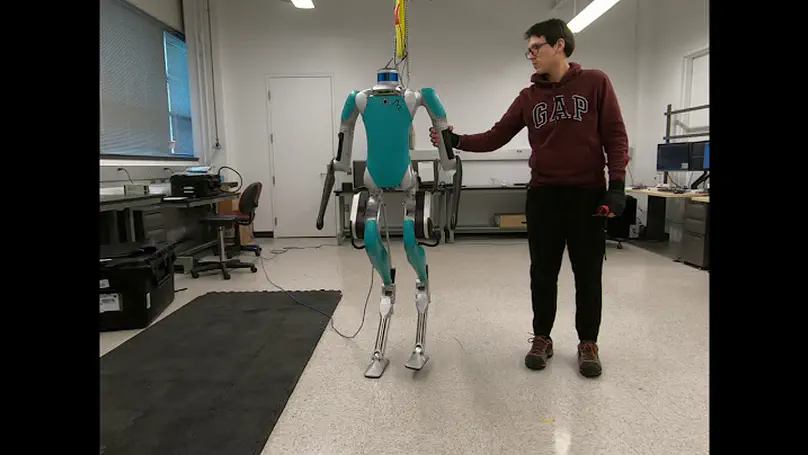
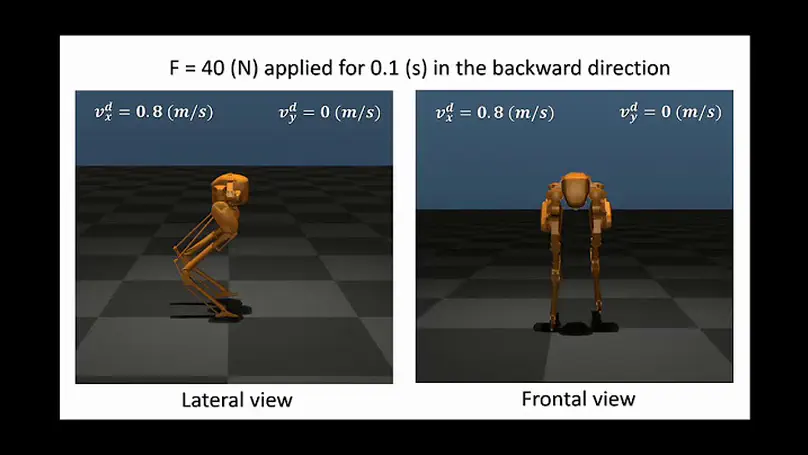
Resolved Motion Control for 3D Underactuated Bipedal Walker using LIP dynamics and Neural Adaptation
Resolved motion control using a linear inverted pendulum model and neural adaptation.
Resolved motion control using a linear inverted pendulum model and neural adaptation.