Learning safer walking
Step-to-step prediction informs reinforcement learning for bipedal locomotion.
Watch & exploreResearch in motion
Research demonstrations and supplementary paper videos.
Follow the Cyberbotics Lab YouTube channel for the latest uploads.
20 videos · newest first
Step-to-step prediction informs reinforcement learning for bipedal locomotion.
Watch & explore
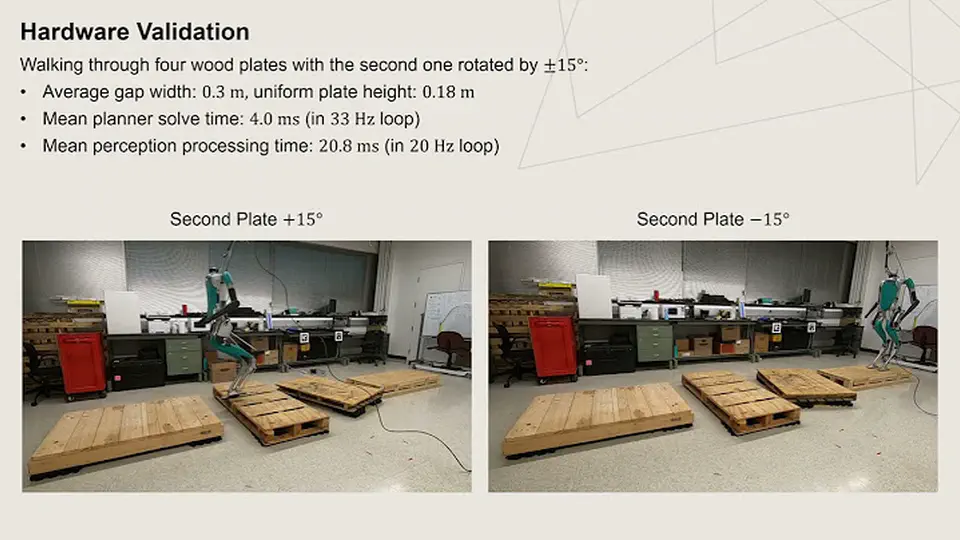
Perception and variable step timing for walking across disconnected footholds.
Watch & explore
Data bootstrapping supports reinforcement learning for dynamic navigation subgoals.
Watch & explore
Linear discrete control barrier functions for safe bipedal robot navigation.
Watch & explore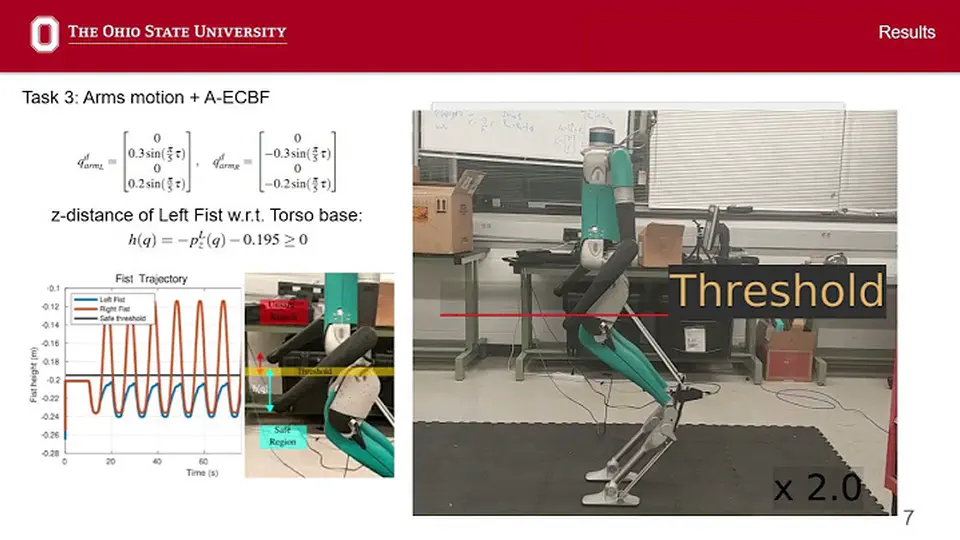
A data-driven latent representation supports bipedal locomotion learning.
Watch & explore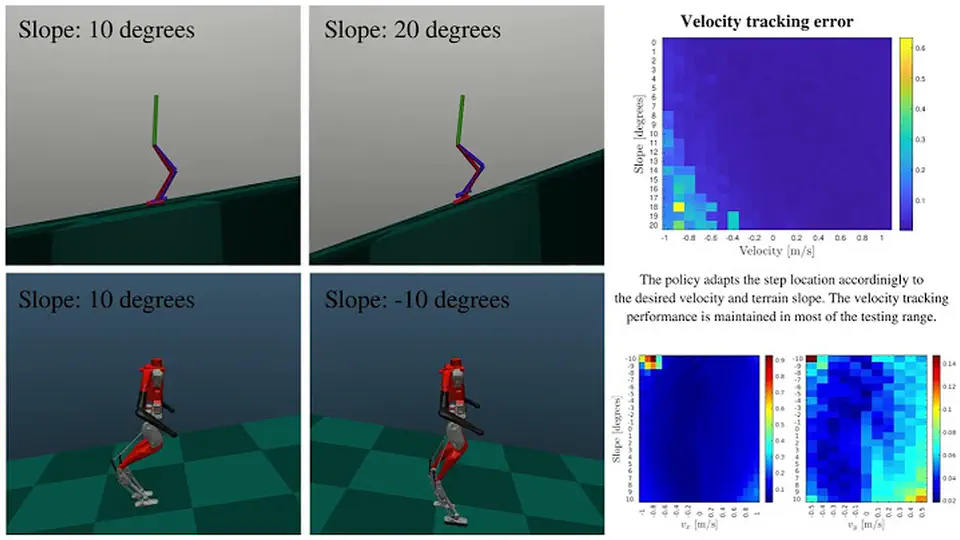
Template models inform task-space learning for bipedal locomotion.
Watch & explore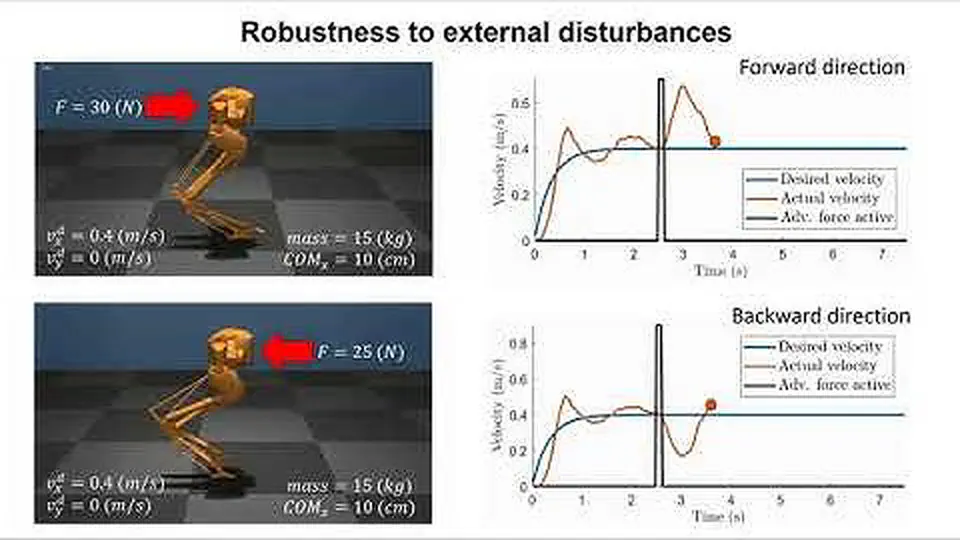
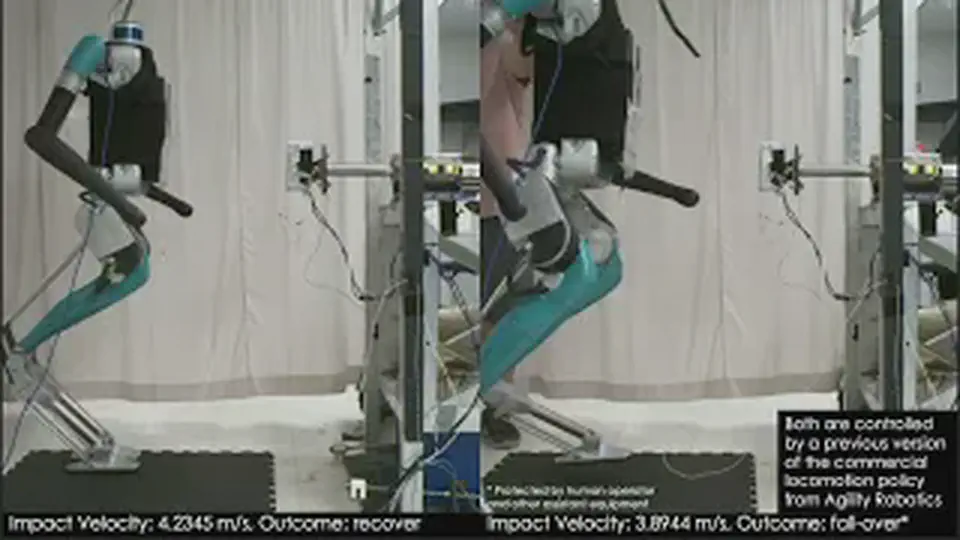
Disturbance-rejection testing of legged locomotion with a linear impactor.
Watch & explore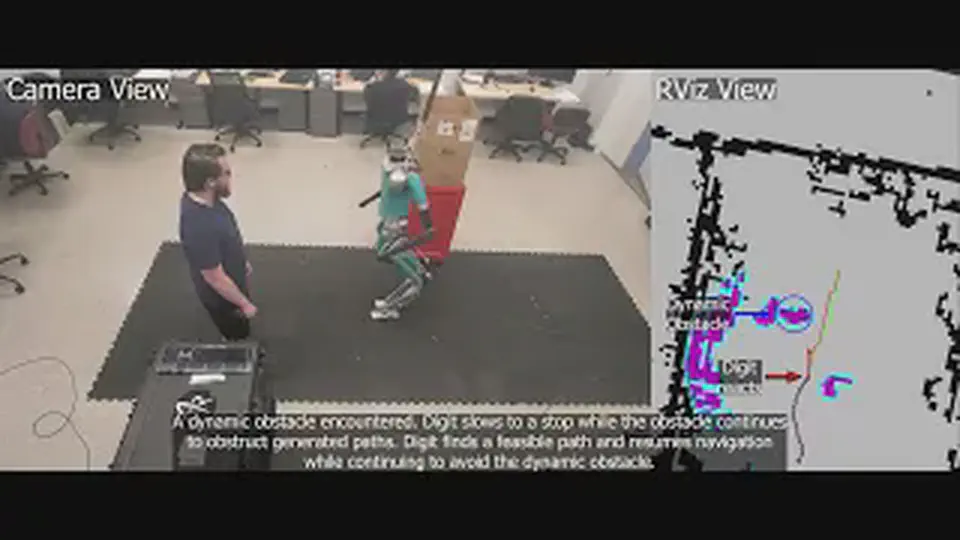
Real-time bipedal robot navigation in dynamic environments.
Watch & explore
Control barrier functions and logistic regression for planning around polynomial-shaped obstacles.
Watch & explore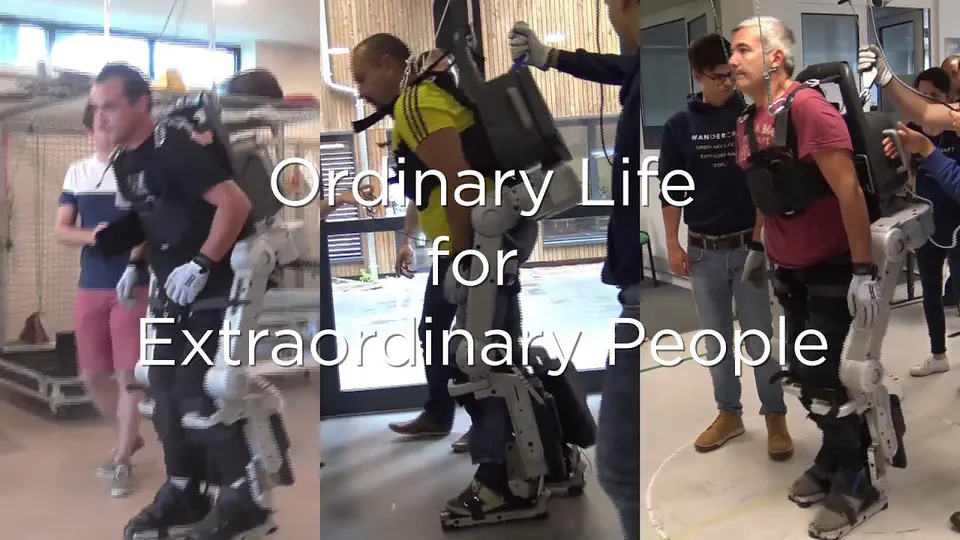
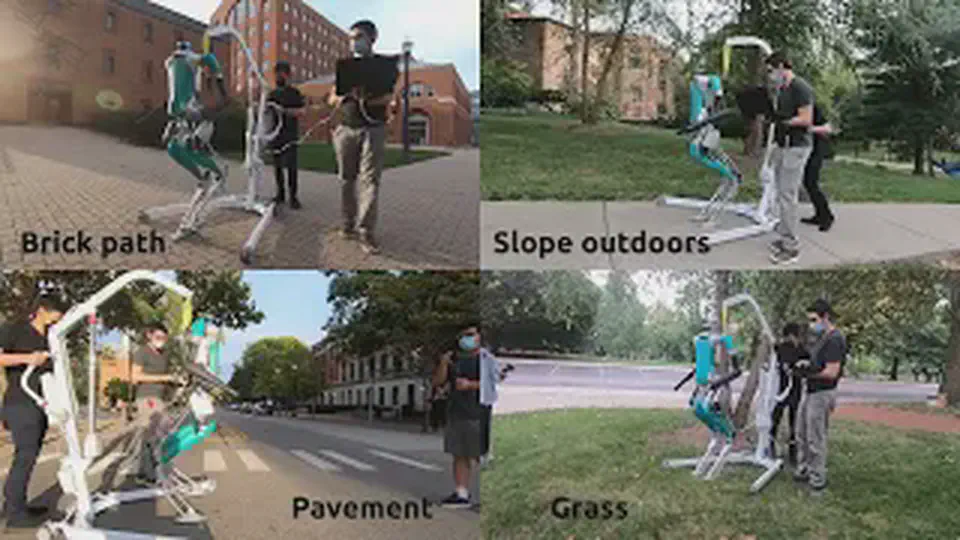
Reinforcement learning and cascade policies for robust bipedal locomotion.
Watch & explore
Resolved motion control using a linear inverted pendulum model and neural adaptation.
Watch & explore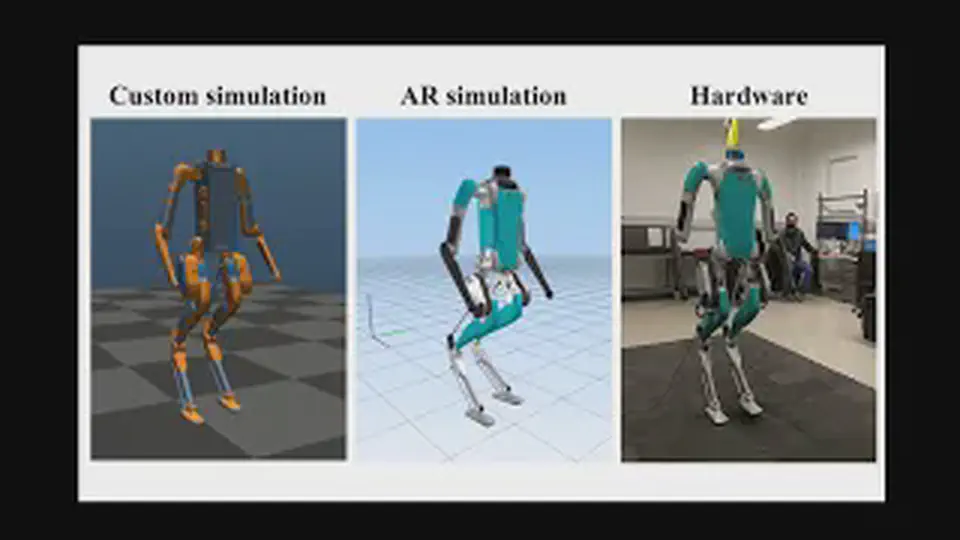
Learned feedback motion policies for Digit walking on rough terrain.
Watch & explore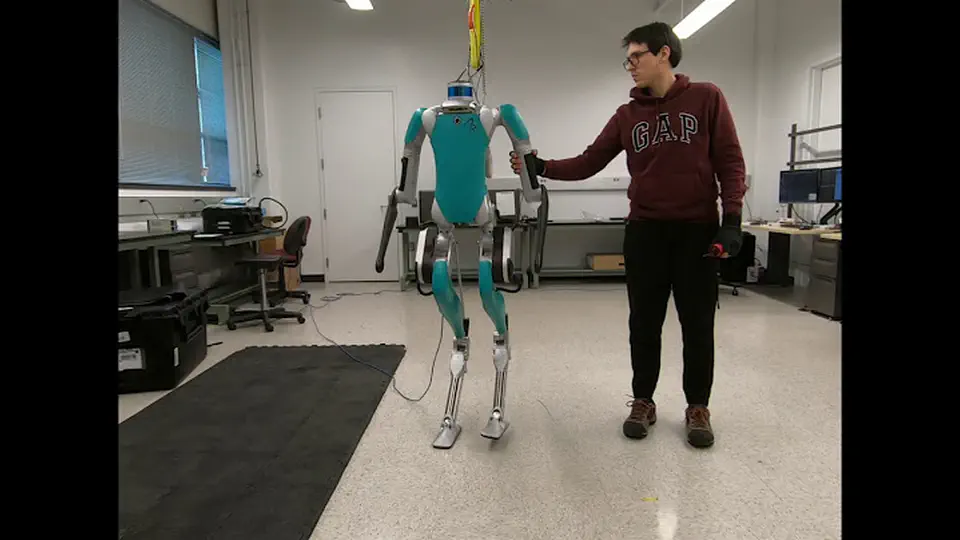
Digit’s first walking gait and small disturbance-rejection tests in the Cyberbotics Lab.
Watch & explore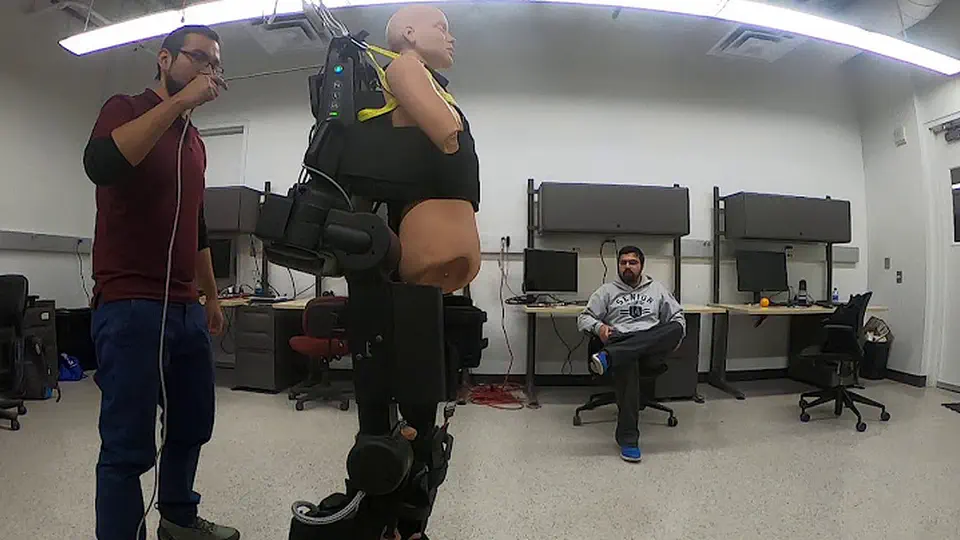
Early exoskeleton walking with the Ohio State controller.
Watch & explore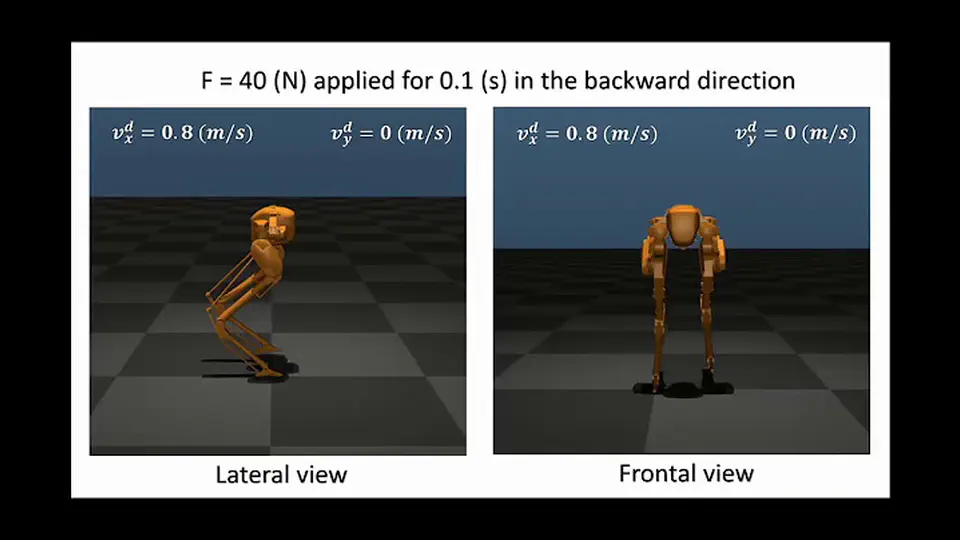
Hybrid zero dynamics informs reinforcement learning for 3D bipedal walking.
Watch & explore